CGV Lab
Computer Graphics and Vision Lab @ Handong Global University.
About
The CGV Lab at Handong Global University develops intelligent systems to perceive and reconstruct the real world. Our research focuses on achieving reliable indoor autonomous driving through advanced perception and neural rendering technologies.
Mission
- Pioneer 3D perception and neural rendering for immersive digital twins.
- Enable high-precision indoor autonomous driving for mobile platforms.
- Bridge research and practice through open-source and real-world deployment.
Research Areas
- Neural Rendering (NeRF, Gaussian Splatting)
- Indoor Autonomous Driving (Localization, Control, Navigation)
- Intelligent Perception (Scene Understanding, 3D Reconstruction)
- Spatial Analysis (Optimization, Geometric Vision)

News
| Nov 01, 2026 |  [Measurement 2026] 1 PAPER PUBLISHED(2026.11) Kim, Sungmin and Lee, Changha and Hwang, Sungsoo, “Length Estimation of Tilted Object Using Ground Point Detection in Single View.” |
|---|---|
| Aug 01, 2026 |  [IEEE CASE 2026] 1 PAPER ACCEPTED(2026.8) Park, Jin Bok and Lee, Jinkyu and Back, Muhyun and Han, Hyun Min and Ma, Tianwei and Won, Sang Min and Hwang, Sung Soo and Chun, Il Yong, “SSIL: Self-Supervised Imitation Learning for End-to-End Driving.” |
| Jun 17, 2026 |  [IEEE Access 2026] 1 PAPER PUBLISHED(2026.6) Yoo, Gunmin and Gu, Hyunwoo and Hwang, Sung Soo, “VOCA: A VLM-Optimized Call Approach for Zero-Shot Navigation Using Target-Context Cues.” |
| Apr 08, 2026 |  [Journal of Forensic Sciences 2026] 1 PAPER ACCEPTED(2026.4) Kim, Sung Min and Lee, Chang Ha and Ga, Briel and Hwang, Sung Soo, “Single-view object height estimation using ground point detection.” |
| Jan 01, 2026 | 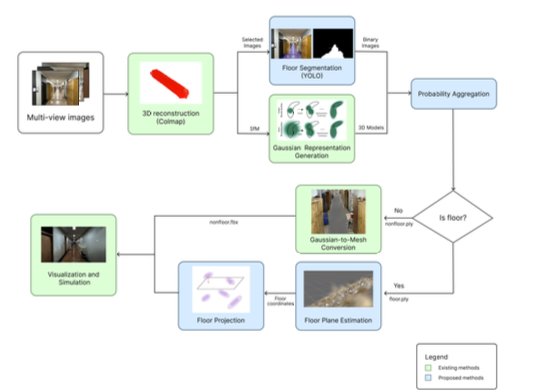 [IEEE AIxVR 2026] 1 PAPER ACCEPTED(2026.1) Sim, Seonghwan and Kim, Yeji and Hwang, Sung Soo, “Stabilizing Robot Simulation via YOLO-based Floor Flattening and Selective Mesh Reconstruction in 3D Gaussian Splatting.” |